How to cite: Krieger A. “Autonomous robots in surgery: how does AI fit in? October 2025. Accessed January 2026. ” October, 2025. Accessed Oct 2026. https://grandroundsinurology.com/autonomous-robots-in-surgery-how-does-ai-fit-in/
Summary
Axel Krieger, PhD, Associate Professor and Carol Croft Linde Faculty Scholar, Malone Center for Engineering in Healthcare, Johns Hopkins University, Baltimore, Maryland, presents work in smart and autonomous robotics designed to assist with rising surgical caseloads and growing workforce shortages. He explains that robotic systems support less invasive procedures by enabling precise instrument control for laparoscopic and single-port access. He notes that minimally invasive surgery offers advantages for patients, including reduced blood loss, improved recovery, and less scarring. However, complication rates have not declined with current teleoperated systems.
He describes a progression toward autonomy in specific surgical tasks. He references a previously established hierarchy of autonomy levels and explains that highly autonomous systems already exist in rigid anatomy, such as orthopedics or laser-based procedures. He states that soft tissue surgery remains challenging due to deformation and variability, creating a large unaddressed space for innovation.
Dr. Krieger describes an earlier model-based approach used in the Smart Tissue Autonomous Robot program, which required target detection, tracking, modeling, and tool control. He notes this method is predictable but difficult to scale and limited by extensive engineering demands.
He then outlines a shift toward learning based methods that rely on imitation learning from expert surgical demonstrations. He explains that this approach allows a single framework to adapt to multiple tasks by incorporating additional data. He reports high success rates in simulated tissue tasks.
Dr. Krieger shares an application of this framework to ex vivo gallbladder surgery, focusing on the clipping and cutting phase of cholecystectomy. He reports successful autonomous completion across multiple specimens, showing progress toward complex autonomous soft tissue procedures.
Frontiers in Oncologic Prostate Care and Ablative Local Therapy (FOCAL) is an outstanding program on prostate imaging, transperineal interventions, and ablative treatments for prostate cancer and benign prostatic hyperplasia. Bringing together community-based, academic, and industry partners, FOCAL offers lectures by world-renowned faculty and hands-on training workshops on in-office transperineal interventions, fusion-guided prostate ablation and state-of-the-art BPH management with novel technologies.
ABOUT THE AUTHOR
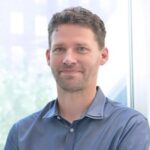
Axel Krieger, PhD, is an Associate Professor of Mechanical Engineering at Johns Hopkins in Baltimore, Maryland. Dr. Krieger specializes in both the fundamental and translational development of novel tools, imaging, and robot control techniques for medical robotics. His research investigates methodologies that increase smartness and autonomy and improve image guidance of medical robots to perform previously impossible tasks, improve efficiency, and ultimately enhance patient outcomes.